Specifications
Protocol :
EtherCAT / CAN
Brand Name :
SENINTER
OD :
90mm
Model Number :
SYT-RI-70-90 CAN
Length :
73mm
Voltage :
24-48VDC
Weight :
1.27kg
Certification :
CE ROHS
Max. Speed :
77RPM
Place of Origin :
CHINA
Max. Torque :
108N·m
Description

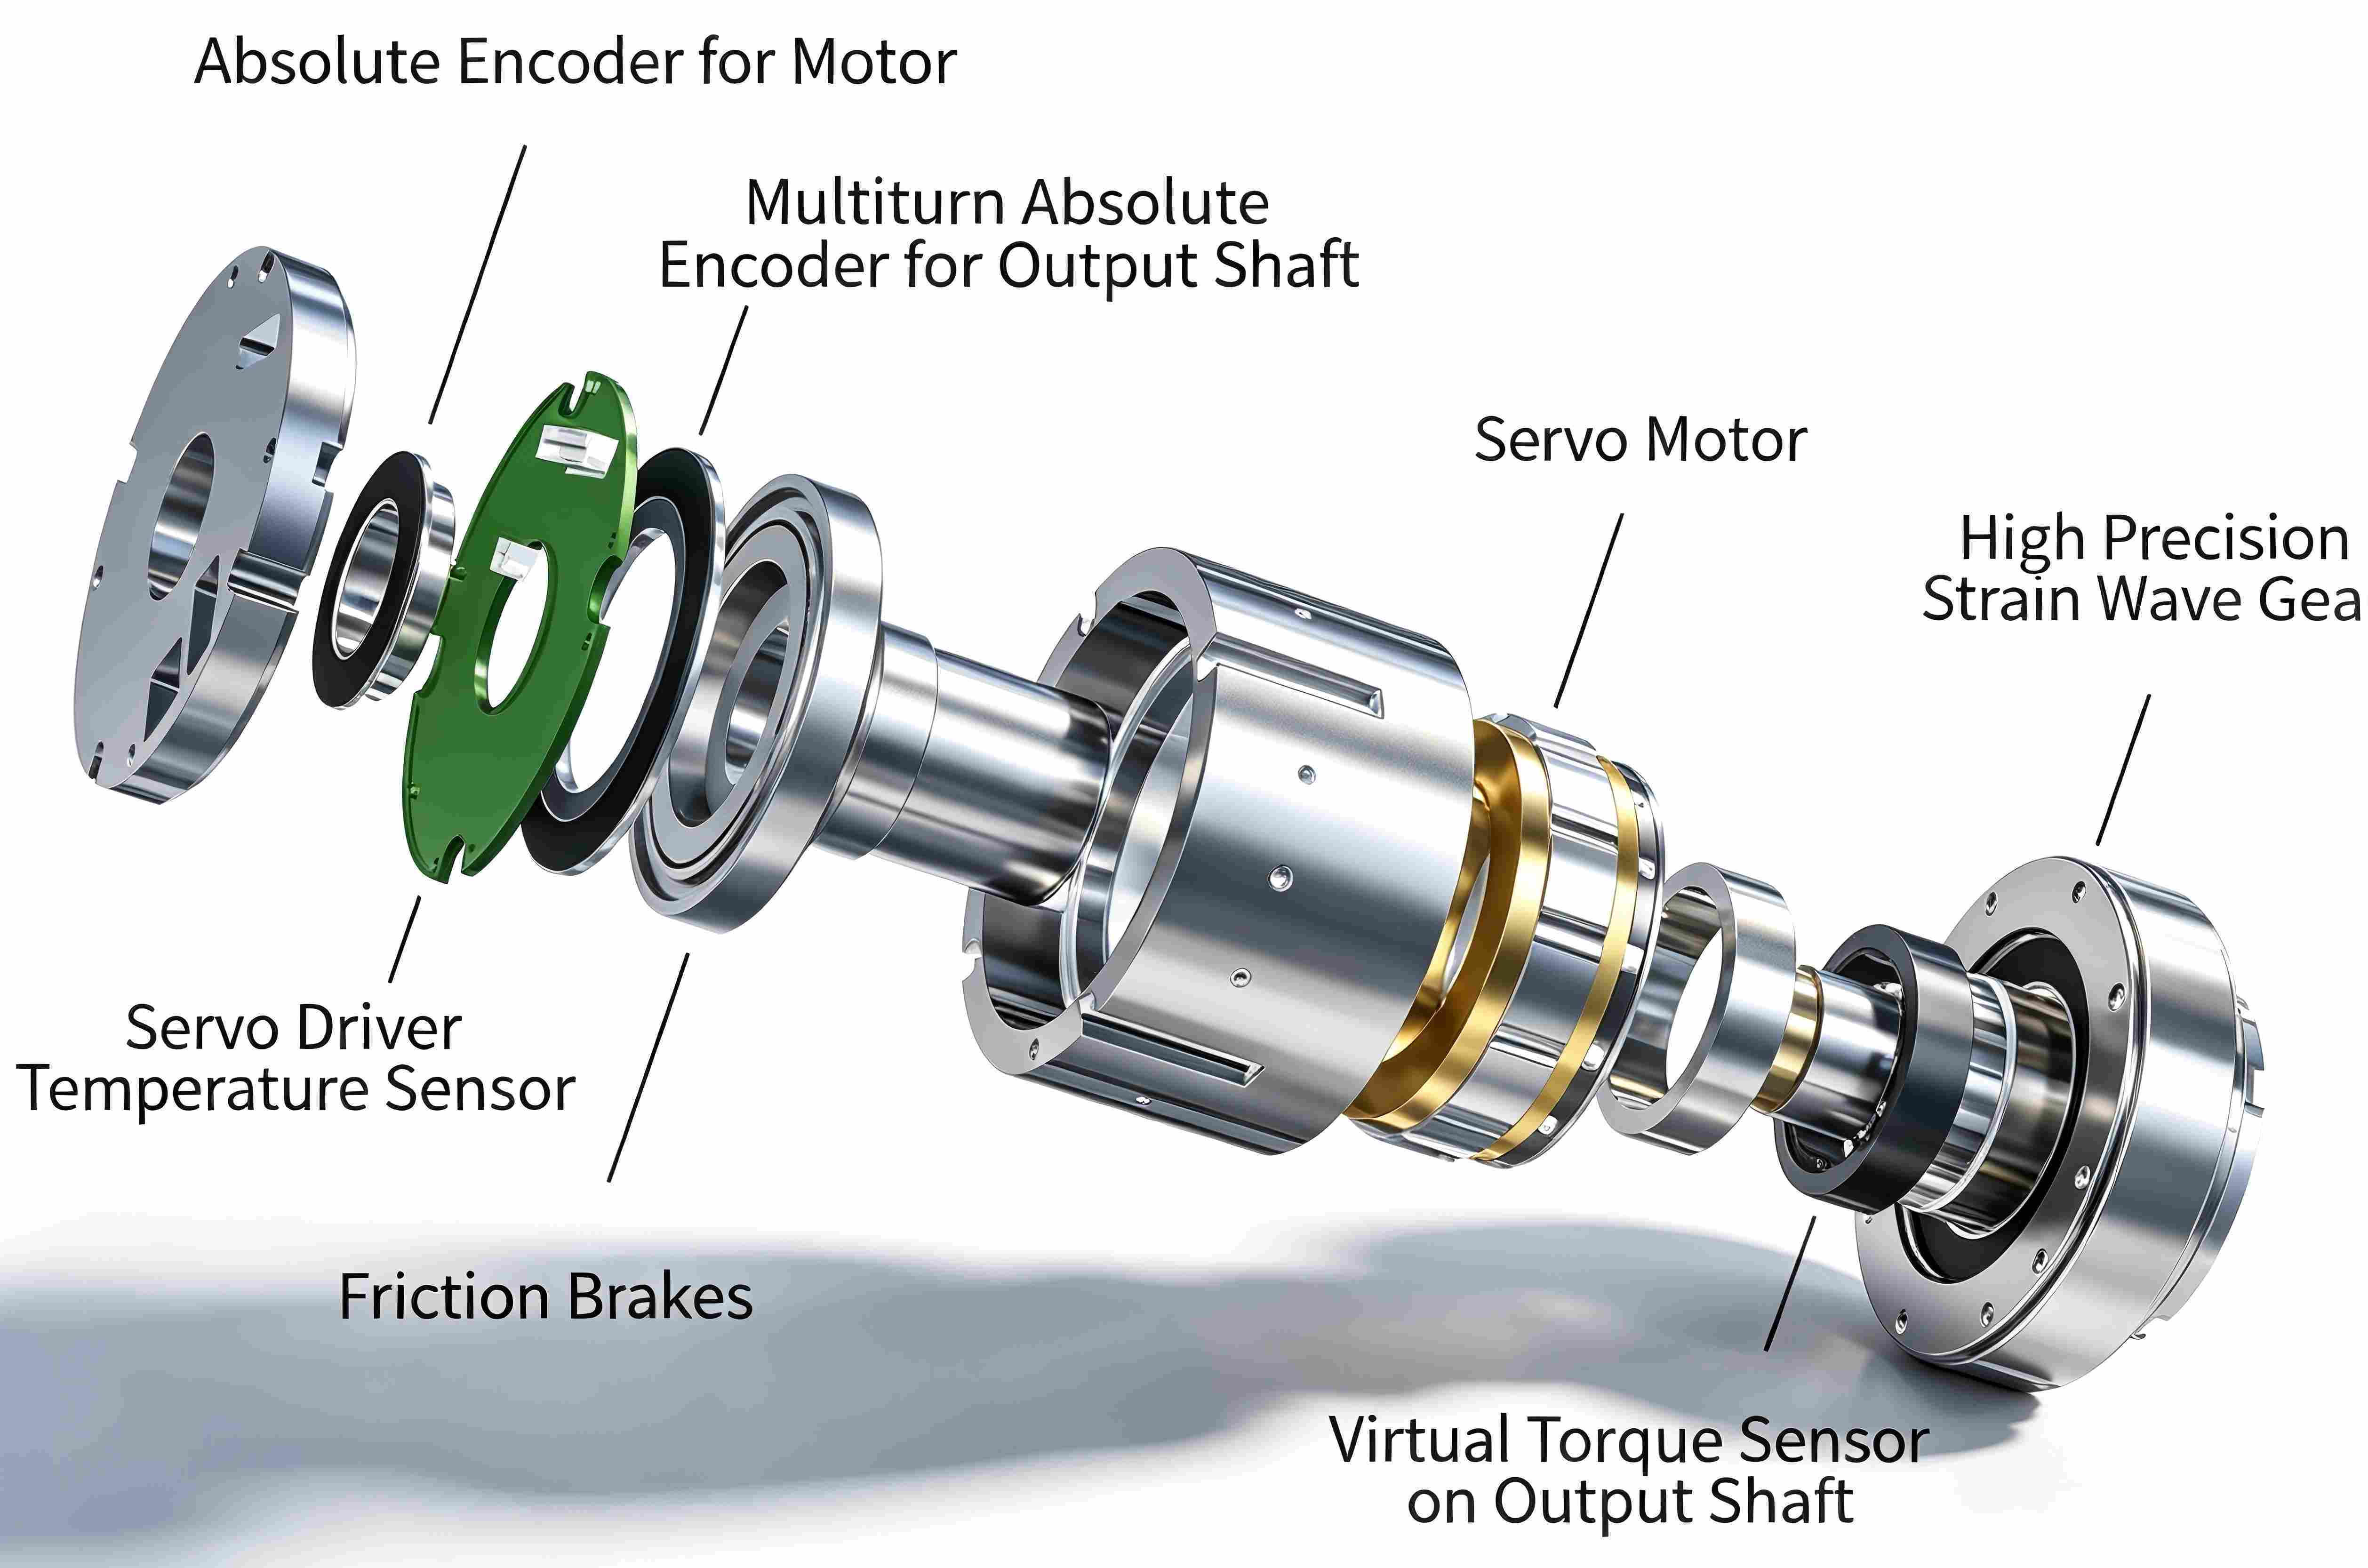
Humanoid Robot Joint Module (Rotary Actuator) Structure – Core Components

Output Flange / Connector – Connects to robot links (e.g., lower leg, forearm), outputs torque and motion.

Torque Sensor (optional but common in high-performance designs) – Ring or spoke type, used for force control / collision detection.

Harmonic Drive – Consists of a wave generator, flexspline, and circular spline; mounted on the motor output shaft.

Frameless Torque Motor – Stator fixed to the housing, rotor connected to the wave generator.

Brake (Safety Holding Brake) – Locks the joint position when power is lost.

Dual Encoders – Motor-side encoder (measures speed/position) and output-side encoder (eliminates reducer backlash error); commonly used for full closed-loop control.

Driver (Servo Drive Board) – Integrated inside the module or in a compact package.

Housing / Cooling Structure – Aluminum alloy body with cable channels.

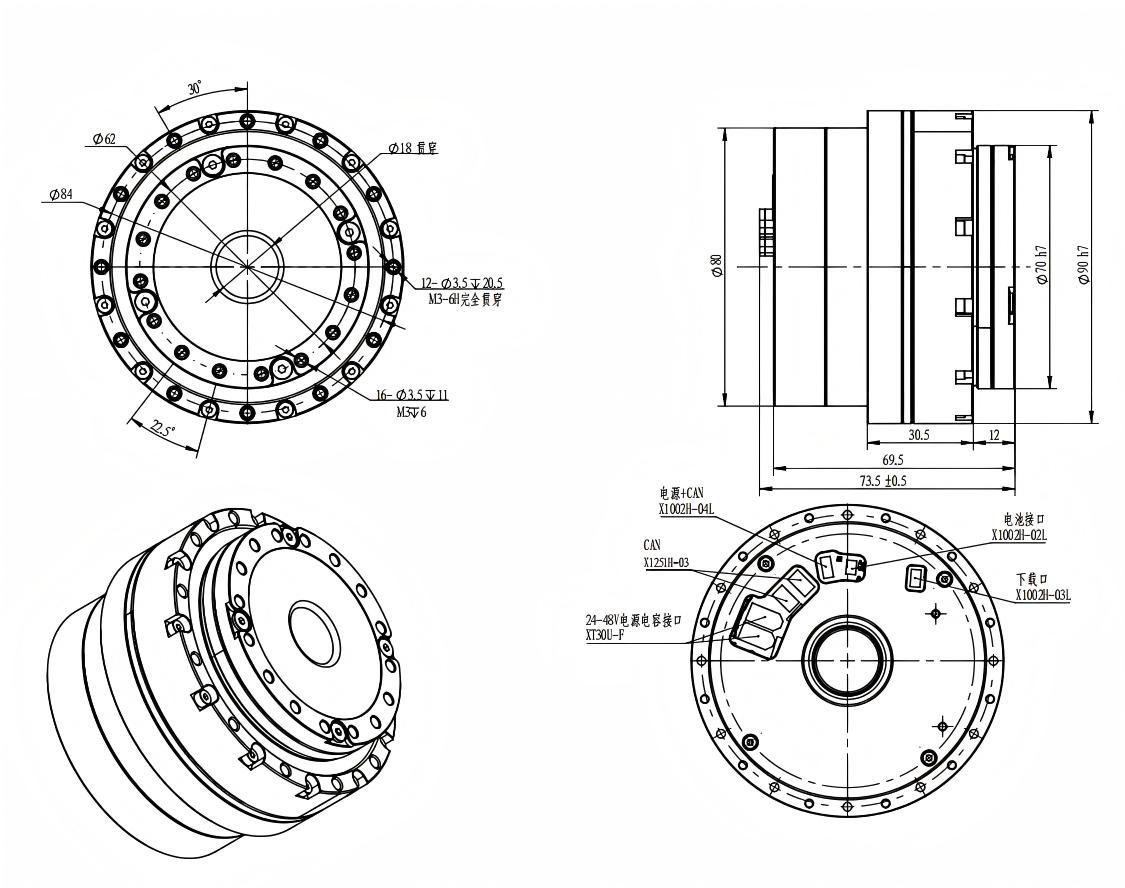
SYT-RI-70-90

Drawing without brake

SYT-RI-70-90


without brake Parameter Table

Parameter Unit Ratio 51 Ratio 81 Ratio 101 Ratio 121
Gear Ratio - 51 81 101 121
Peak Torque N·m 69 91 102 108
Max Allowable Torque At Average Load (Robot Application) N·m 42 58 61 61
Rated Torque @ 2000RPM (Industrial Application) N·m 32 42 50 50
Peak Output Speed RPM 77 48 40 30
Rated Speed (With 1/2 Rated Torque) RPM 61 38 30 25
Gear Backlash arcsec 20 20 10 10
Rated Power W 500 500 500 500
Supply Voltage V 24–48 24–48 24–48 24–48
Max Continuous Current A 8.4 8.4 8.4 8.4
Rated Current A 6.1 6.1 6.1 6.1
Torque Constant N·m/A 0.118 0.118 0.118 0.118
Encoder Resolution bit 16 16 16 16
Communication Bus - CAN CAN CAN CAN
Hollow Shaft Diameter mm 18 18 18 18
Total Length mm 73.5±0.5 73.5±0.5 73.5±0.5 73.5±0.5
Mass kg 1.27 1.27 1.27 1.27
Rotational Inertia g·cm² 596.4 596.4 596.4 596.4

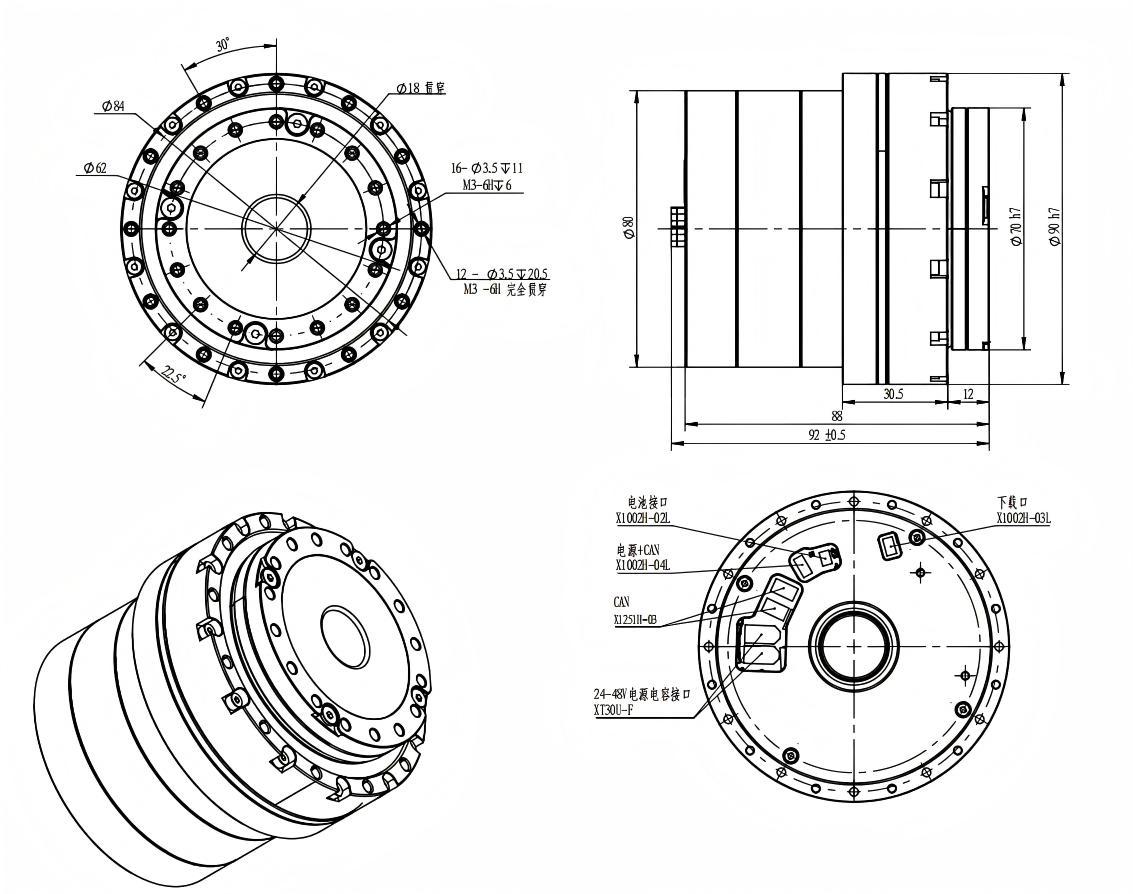
Drawing with brake


SYT-RI-70-90


With brake Parameter Table


Parameter Unit Ratio 51 Ratio 81 Ratio 101 Ratio 121
Gear Ratio - 51 81 101 121
Peak Torque N·m 69 91 102 108
Max Allowable Torque At Average Load (Robot Application) N·m 42 58 61 61
Rated Torque @ 2000RPM (Industrial Application) N·m 32 42 50 50
Peak Output Speed RPM 77 48 40 30
Rated Speed (With 1/2 Rated Torque) RPM 61 38 30 25
Gear Backlash arcsec 20 20 10 10
Rated Power W 500 500 500 500
Supply Voltage V 24–48 24–48 24–48 24–48
Max Continuous Current A 8.4 8.4 8.4 8.4
Rated Current A 6.1 6.1 6.1 6.1
Torque Constant N·m/A 0.118 0.118 0.118 0.118
Encoder Resolution bit 16 16 16 16
Communication Bus - CAN CAN CAN CAN
Hollow Shaft Diameter mm 18 18 18 18
Total Length mm 92±0.5 92±0.5 92±0.5 92±0.5
Mass kg 1.5 1.5 1.5 1.5
Rotational Inertia g·cm² 746.7 746.7 746.7 746.7


Send your message to this supplier
Send Now

SYT-RI-70-90

Ask Latest Price
Protocol :
EtherCAT / CAN
Brand Name :
SENINTER
OD :
90mm
Model Number :
SYT-RI-70-90 CAN
Length :
73mm
Voltage :
24-48VDC
Contact Supplier
SYT-RI-70-90

Shenzhen Seninter Precision Machinery Co.,Ltd.

Verified Supplier
1 Years
guangdong, shenzhen
Since 2017
Business Type :
Manufacturer
Total Annual :
10 million USD-15million USD
Employee Number :
100~300
Certification Level :
Verified Supplier
Discover similar products
View More
Contact Supplier
Submit Requirement