Specifications
Teeth profile :
Gleason
Product name :
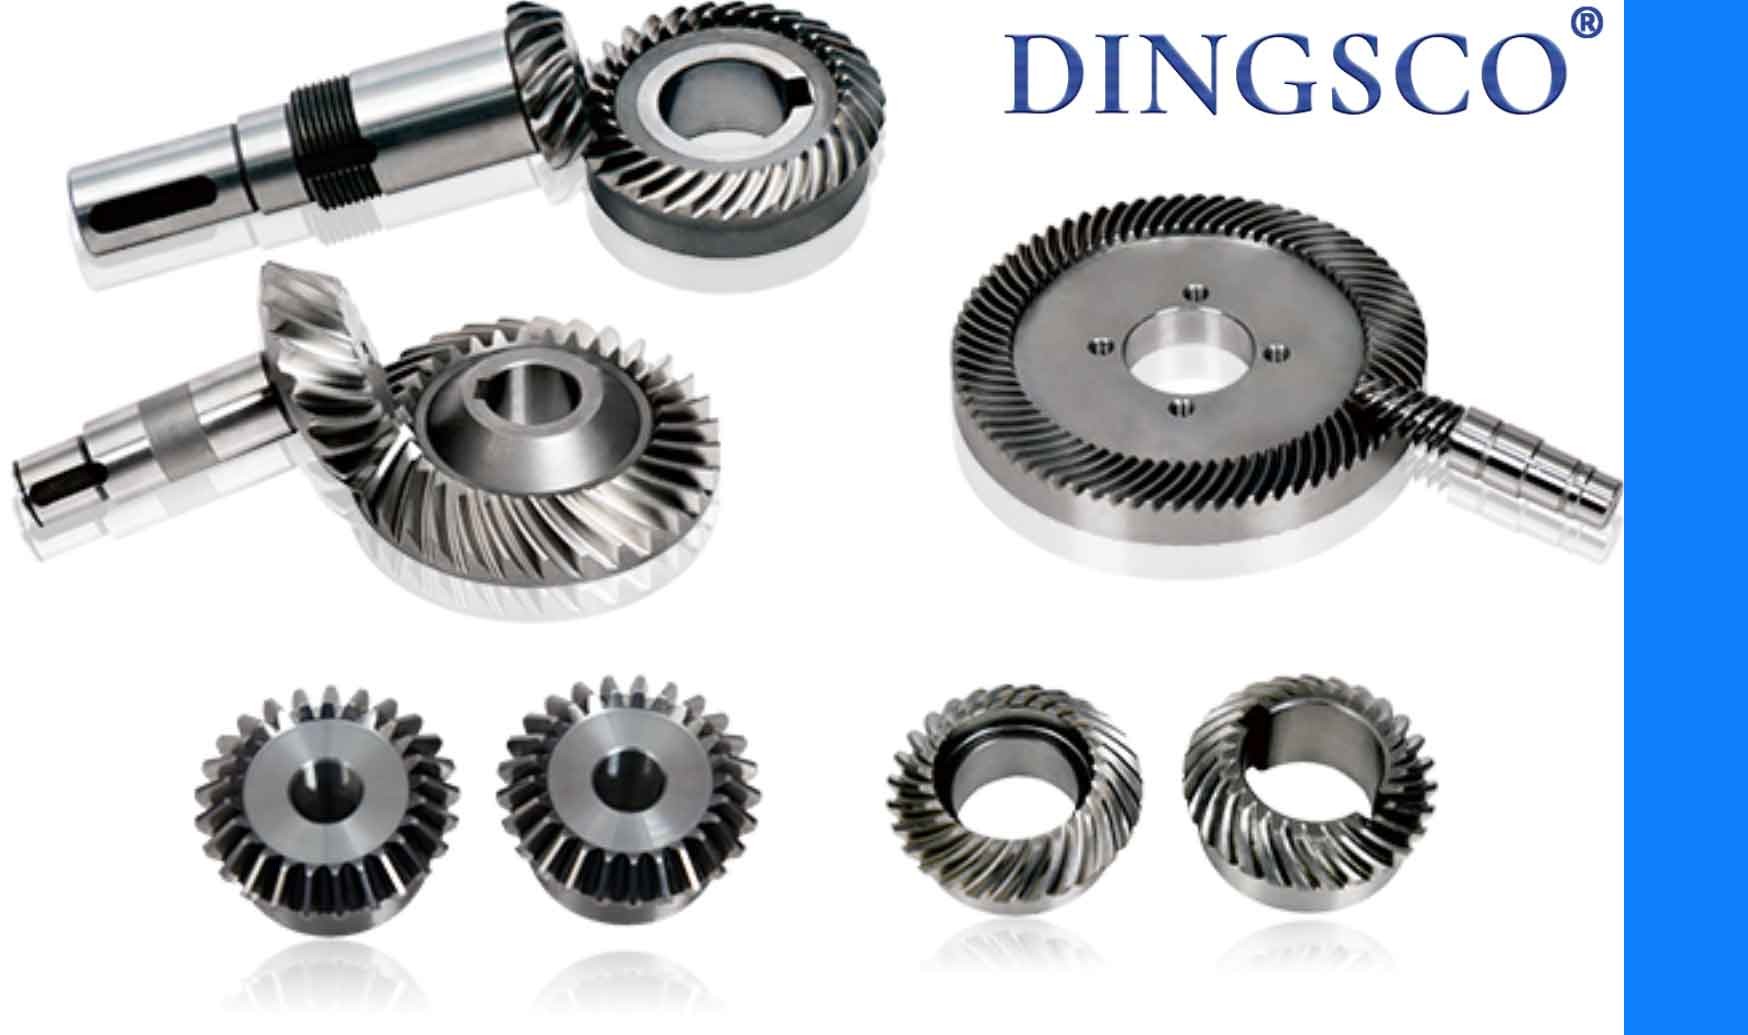
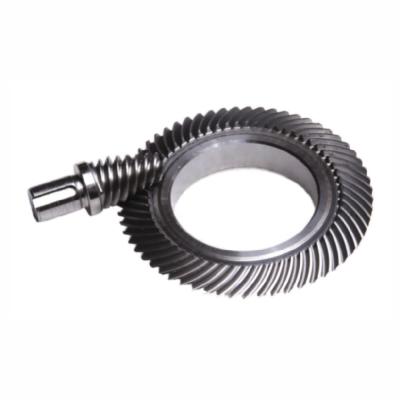
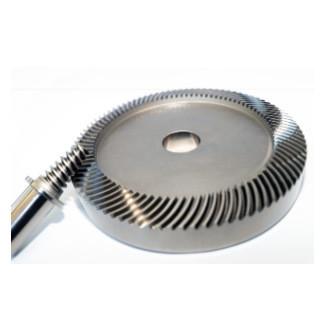
Quasi-Hypoid Gear Spiral Tooth Meshing For Robotic Joint reducer
Application :
Robotic joint reducer
Type :
Quasi-Hypoid Gear
Function :
Speed reduction with Torque increase + Directional transmission
Brand Name :
DINGSCO
Model Number :
According to customers' requests
Certification :
ISO 9001
Place of Origin :
Changsha, China
MOQ :
Negotiable
Price :
Negotiable
Payment Terms :
T/T
Supply Ability :
Negotiable
Delivery Time :
(Sample order) 7 days
Packaging Details :
According to customers' requests
Meshing :
Spiral tooth meshing
Description

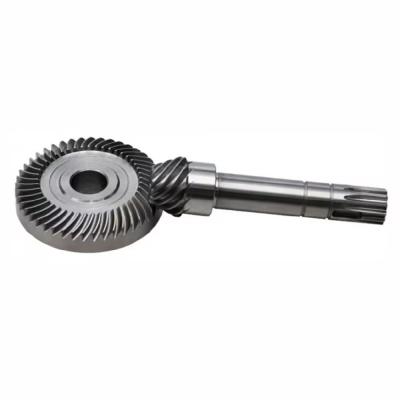
Quasi-Hypoid Gear Spiral Tooth Meshing For Robotic Joint reducer

This quasi - hypoid gear pair is a core component of robotic joint reducers, and can be introduced from the following aspects:

1. Structural & Transmission Logic
It consists of a small quasi - hypoid gear (with an ultra - long shaft) and a large quasi - hypoid gear. The two shafts are orthogonally staggered (perpendicular and offset), and power transmission is achieved through spiral tooth meshing. It can efficiently complete "speed reduction with torque increase + directional transmission" — converting the "high - speed, low - torque" of the motor into "low - speed, high - torque" at the joint while changing the rotation direction.

2. Core Performance Advantages
▶High Transmission Efficiency: With a transmission efficiency of over 95%, it is significantly more efficient than worm gear transmission, reducing energy consumption for robotic operations.
▶Strong Load - Bearing Capacity: The spiral teeth achieve continuous meshing with a high contact ratio, increasing the tooth surface contact area and enabling it to bear large torques, which meets the heavy - load motion needs of robots.
▶Low Noise & High Precision: The arc - tooth structure reduces noise by about 20 dB. Combined with precision grinding processes, it can ensure micron - level transmission accuracy, laying a foundation for the robot's precise positioning.

3. Application in Robotic Joints
It is widely used in robotic joints, especially in:
▶Humanoid/Collaborative Robots: In compact joints such as wrists and elbows, its "compact structure + high torque" characteristic helps reduce the joint volume while ensuring power output.
▶Industrial Robots: In heavy - duty joints, its high efficiency and load - bearing capacity support long - term continuous operation.


Dimension Structure and Form Performance
Overall Composition Small hypoid gear (with ultra-long shaft) + large hypoid gear, orthogonally staggered shaft layout Transmission efficiency >95%; High-contact-ratio spiral teeth for strong load capacity; Spiral teeth + grinding reduce noise and ensure micron-level precision
Core Transmission Logic Power transmission via spiral tooth meshing, achieving "speed reduction with torque increase + direction change" Efficiently convert motor's "high-speed, low-torque" to joint's "low-speed, high-torque" while changing rotation direction
Details of Performance Advantages Continuous meshing of spiral teeth, orthogonally staggered shaft design Efficiency superior to worm gear transmission; Large tooth surface contact area; Grinding ensures micron-level precision, and spiral teeth reduce noise by ~20 dB
Scenario Adaptation Logic Compact structure + high torque density Output large torque in a small space, balancing flexibility and power
Role in Industrial Development Breakthrough in domestic precision gear technology Performance matches international brands, achieving technical replacement


DINGSCO Precision Gear Solutions — Pioneering Force in Equipment Transmission

Core Advantages: Cutting-Edge Equipment × Digitalized Processes × Full-Cycle Services


As a leading precision gear manufacturer, DINGSCO specializes in customized production of micro high-precision spiral bevel gears and hypoid gears through our multiple CNC seven-axis five-linkage spiral bevel gear grinding/milling machines and Gleason spiral bevel cutter technology. With DIN 6 precision class (tooth profile error ≤ ±5μm), 95%+ transmission efficiency, and ultra-high reduction ratios, we deliver reliable transmission solutions for robotics, motor drives, new energy vehicles, and more.
Quasi-Hypoid Gear with Spiral Tooth Meshing for Robotic Joint Reducer Featuring DIN 6 Precision Class
Why Choose DINGSCO?
✅ High Precision: Achieving DIN 6 grade accuracy, leading the industry in controlling tooth profile errors.
✅ High Efficiency: With a single - stage reduction ratio of up to 300:1, and a transmission efficiency of over 95%.
✅ Durability: 40% lower lifecycle cost, <0.5% failure rate.
✅ Fast response: The digital process can shorten the delivery cycle to 20 working days.

Contact Us Soon for gear optimization proposals and 3D meshing simulations!

Quasi-Hypoid Gear with Spiral Tooth Meshing for Robotic Joint Reducer Featuring DIN 6 Precision Class

Send your message to this supplier
Send Now

Quasi-Hypoid Gear with Spiral Tooth Meshing for Robotic Joint Reducer Featuring DIN 6 Precision Class

Ask Latest Price
Teeth profile :
Gleason
Product name :
Quasi-Hypoid Gear Spiral Tooth Meshing For Robotic Joint reducer
Application :
Robotic joint reducer
Type :
Quasi-Hypoid Gear
Function :
Speed reduction with Torque increase + Directional transmission
Brand Name :
DINGSCO
Contact Supplier
Quasi-Hypoid Gear with Spiral Tooth Meshing for Robotic Joint Reducer Featuring DIN 6 Precision Class

Hunan Dinghan New Material Technology Co., LTD

Verified Supplier
3 Years
hunan, changsha
Since 1994
Business Type :
Manufacturer, Exporter, Seller
Total Annual :
70 million-100 million
Employee Number :
50~60
Certification Level :
Verified Supplier
Contact Supplier
Submit Requirement